Geared-Up · Pu Tai Senior High School · Team 10002X
Autonomous control
and robot iteration.
I competed in VEX Robotics for three years and mentored underclassmen for one year. The 2021–22 notebook identifies me as the main programmer; the 2023 team biography records my later role as captain.
My contributions
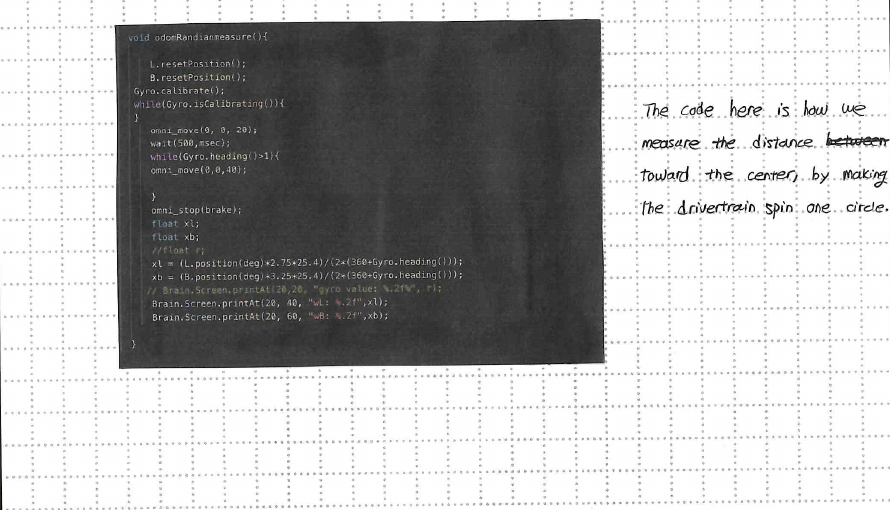
- Co-developed tracking-wheel and gyro-based odometry with a teammate, including a rotation routine to estimate tracking-wheel offsets.
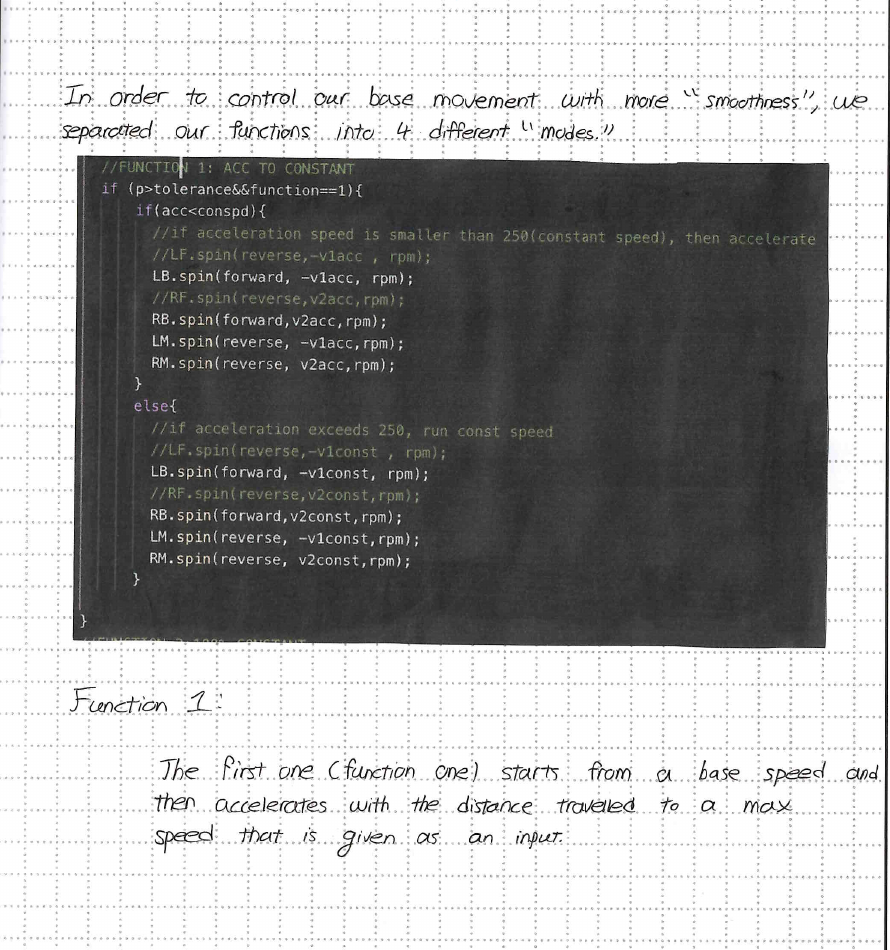
- Developed modular C++ autonomous motion routines with four modes: acceleration to constant speed, constant speed, deceleration, and combined acceleration/deceleration.
- Proposed a pneumatic ring-handling mechanism and collaborated on prototype iteration and robot integration.
Design iteration
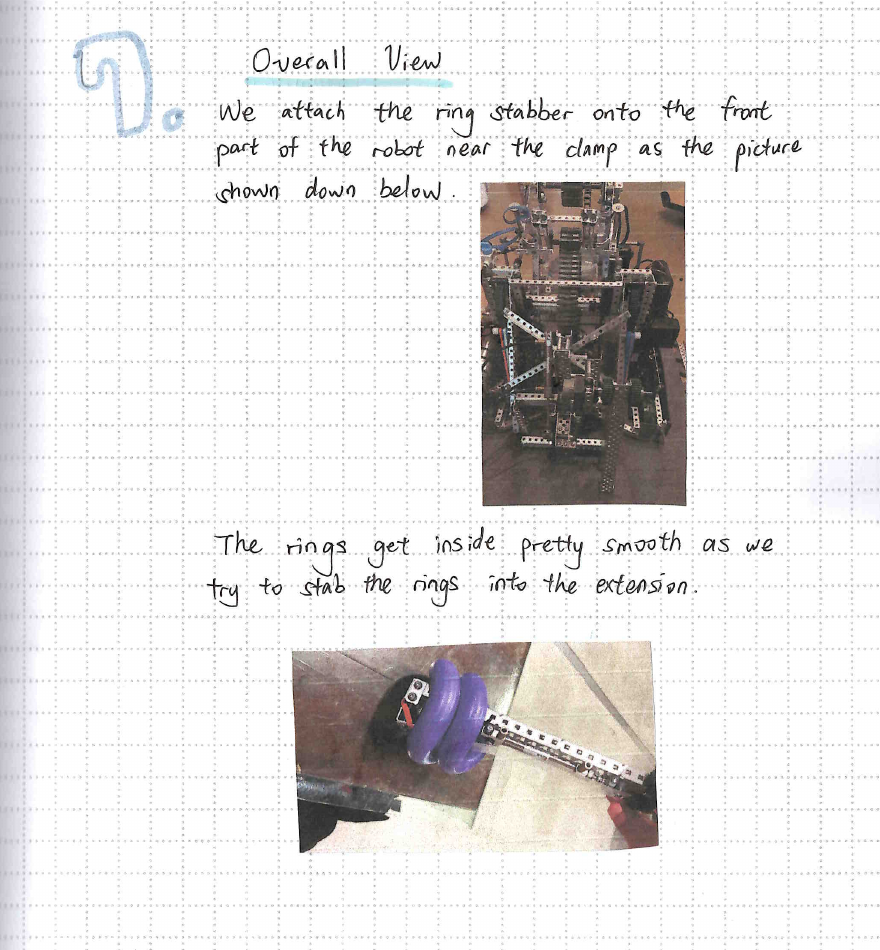
The initial ring-container concept used passive pickup and a pneumatic release. Testing exposed friction that made pickup and reset difficult. The team refined the mechanism with a one-way trapdoor and integrated it near the robot's front clamp.
The control routines were used to combine movement segments during autonomous operation. The notebook records qualitative observations; it does not establish a measured localization error or a quantified performance improvement.
A teammate and I developed the tracking algorithm. Teammates identified friction and release issues during prototype testing and proposed the trapdoor refinement. These were collaborative engineering decisions.
Engineering notebook excerpts
Click any excerpt to inspect it at full size.